 Unitree
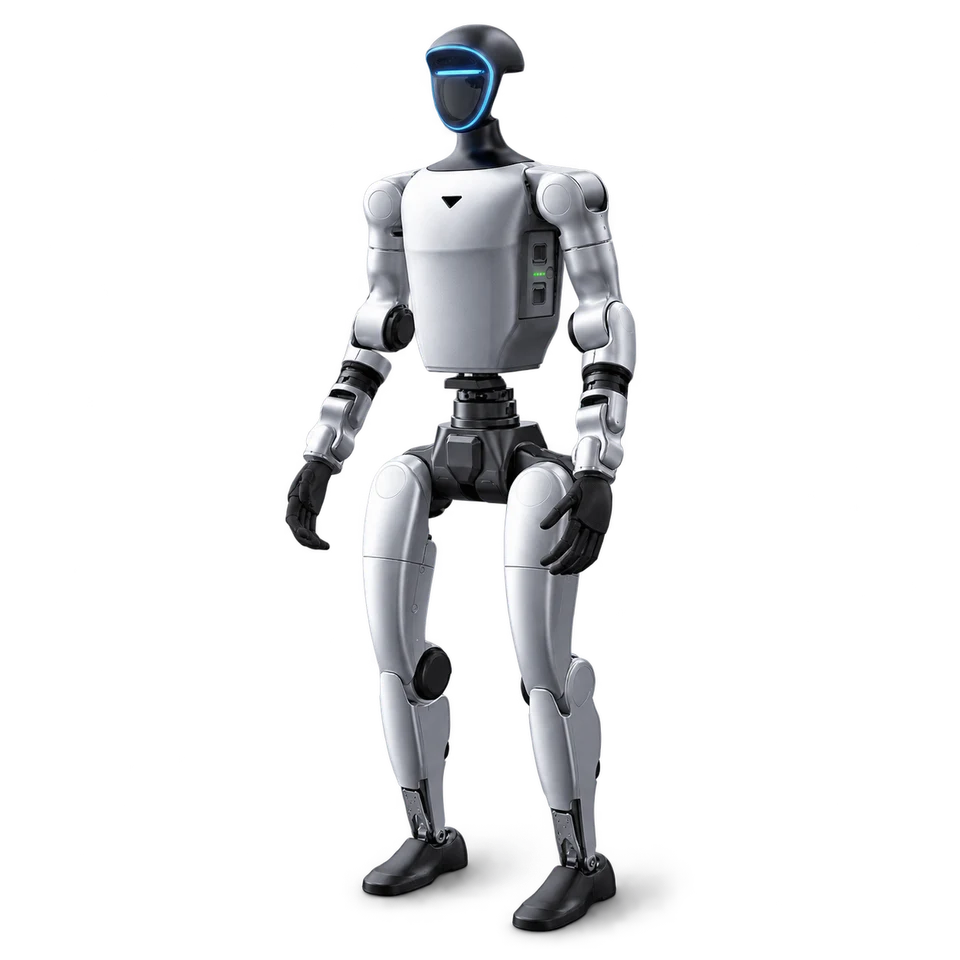
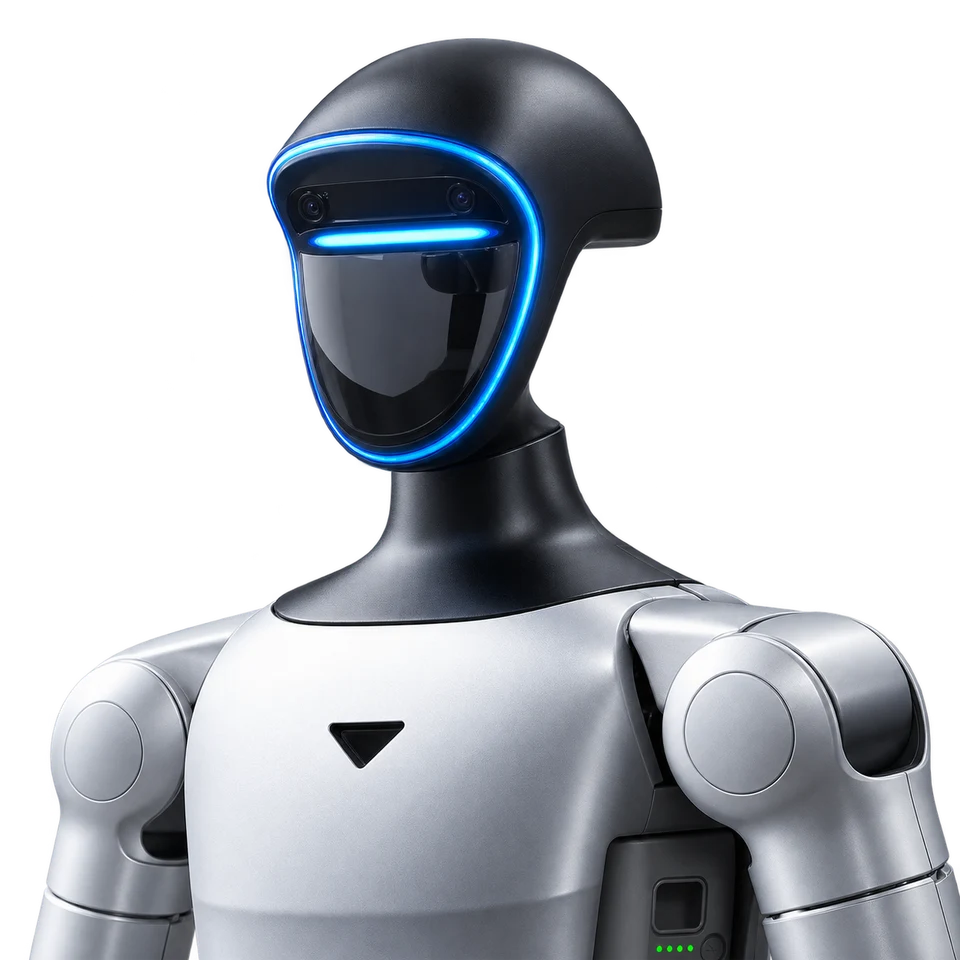
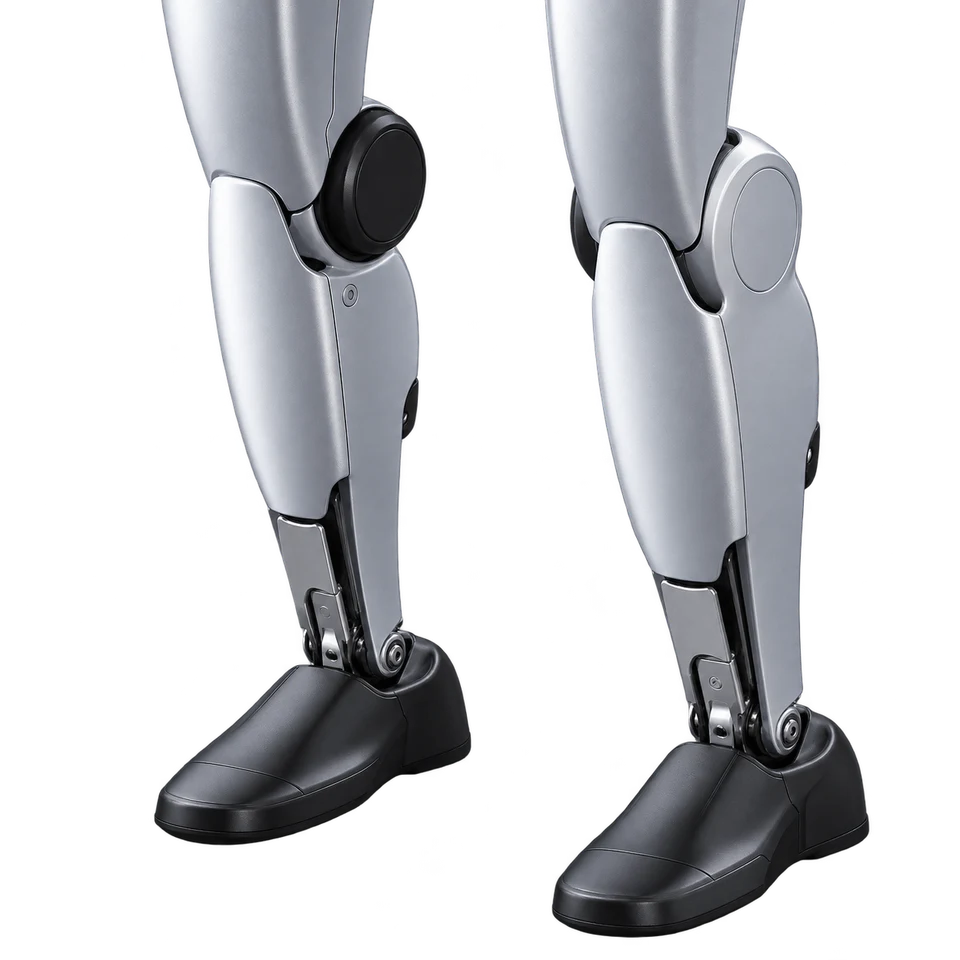
G1
Compact humanoid offered in base and EDU configurations. Secondary development and optional dexterous hands belong to EDU.
- Form
- humanoid
- Purpose
- Humanoid development
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Actuation | ||
| Maximum knee torque | 90 N·m base G1; 120 N·m EDU | 2026-10-27 |
| Waist joints | 1 DoF base G1; EDU optionally adds 2 further waist axes | 2026-10-27 |
| Compute | ||
| Processor | 8-core CPU; additional compute modules offered for EDU | 2026-10-25 |
| Configuration | ||
| Hands | Dex3-1 force-controlled hands optional on EDU; not included on base G1 | 2026-10-25 |
| Joint degrees of freedom | 23 (G1); 23–43 (EDU, configuration dependent) | 2026-10-25 |
| Leg / arm joints | 6 DoF per leg; 5 per arm | 2026-10-25 |
| Connectivity | ||
| Wireless | Wi-Fi 6 and Bluetooth 5.2 | 2026-10-25 |
| Development | ||
| Secondary development | EDU only; not listed for base G1 | 2026-10-25 |
| Interaction | ||
| Audio | Four microphones and 5 W speaker | 2026-10-25 |
| Manipulation | ||
| Arm load | About 2 kg (G1); about 3 kg (EDU). Depends on arm extension and posture. | 2026-10-25 |
| Physical | ||
| Folded dimensions | 690 × 450 × 300 mm | 2026-10-25 |
| Mass with battery | About 35 kg (G1); 35 kg+ (EDU) | 2026-10-25 |
| Standing dimensions | 1320 × 450 × 200 mm | 2026-10-25 |
| Power | ||
| Battery | 9,000 mAh quick-release | 2026-10-25 |
| Charger | 54 V, 5 A | 2026-10-27 |
| Runtime | About 2 hours; varies with use and configuration | 2026-10-25 |
| Purchase | ||
| Availability and region | Research/development platform advertised with base pricing; confirm variant and regional delivery with Unitree. | 2026-10-25 |
| Pricing basis | US$13,500 base G1; excludes tax and shipping. EDU is quote-only. | 2026-10-25 |
| Sensors | ||
| Perception | Depth camera and 3D LiDAR | 2026-10-25 |
Evidence map
2 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | 1 | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | 1 | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
2 of 2 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Unfamiliar-object grasping Unfamiliar-object grasping · manufacturer claimDexterous manipulation is advertised with optional EDU hands; base G1 has no dexterous hand in the specification table. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-27 |
Working runtime Working runtime · manufacturer claimUnitree lists about 2 hours of battery life; workload and test protocol are unspecified. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-27 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.