 Hiwonder
PuppyPi Standard Kit (Pi 5, 4GB)
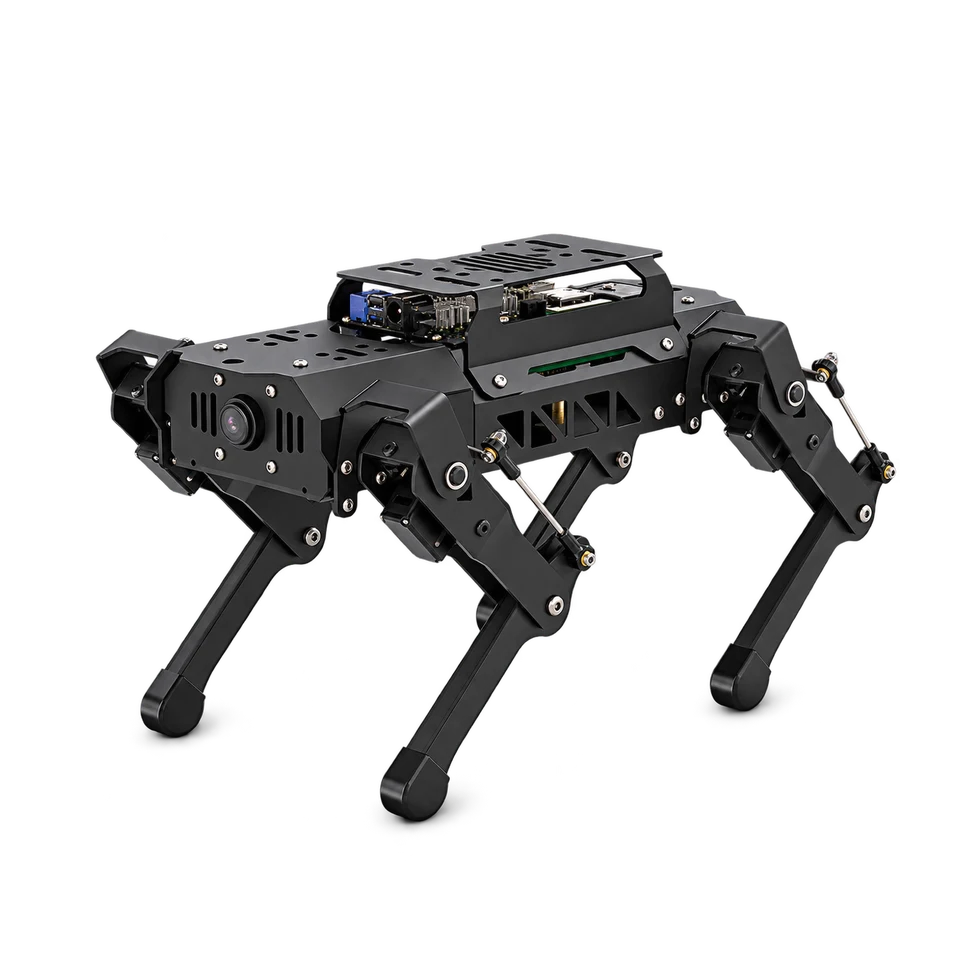
Compact open-frame quadruped for Python and ROS projects. This Standard Kit uses Raspberry Pi 5 with 4GB RAM; lidar, robotic arm and higher-kit sensor expansions are separate.
- Form
- quadruped
- Purpose
- ROS education & vision programming
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Actuation | ||
| Leg servos | HPS-0618SG coreless servos | 2026-10-27 |
| Configuration | ||
| Kit and controller | Standard Kit; Raspberry Pi 5, 4GB RAM | 2026-10-27 |
| Optional expansion | Lidar and robotic arm require higher kits or additional hardware | 2026-10-27 |
| Development | ||
| Operating systems | Ubuntu 22.04 / ROS Humble and Ubuntu 20.04 / ROS Noetic; Pi 5 supports ROS1 and ROS2 | 2026-10-27 |
| Programming | Python with OpenCV; source code and tutorials provided | 2026-10-27 |
| Mobility | ||
| Leg degrees of freedom | 8 | 2026-10-27 |
| Physical | ||
| Dimensions | 226 × 149 × 190 mm, published platform dimensions | 2026-10-27 |
| Mass | 720 g, published platform weight; accessories change weight | 2026-10-27 |
| Structure | Aluminium alloy frame with linkage legs | 2026-10-27 |
| Power | ||
| Battery | 7.4 V, 2,200 mAh LiPo | 2026-10-27 |
| Purchase | ||
| Availability and region | Selected variant is available in the official international store; shipping eligibility and duties depend on destination. | 2026-10-27 |
| Pricing basis | US$626.99 for Standard Kit with Raspberry Pi 5 (4GB), official USD variant data; tax and import duties extra. | 2026-10-27 |
| Sensors | ||
| Camera resolution | 480P in specification table | 2026-10-27 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | 1 | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Room navigation Room navigation · manufacturer claimHiwonder provides camera-based line-following and target-tracking projects for PuppyPi. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-27 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.