 Xiaomi
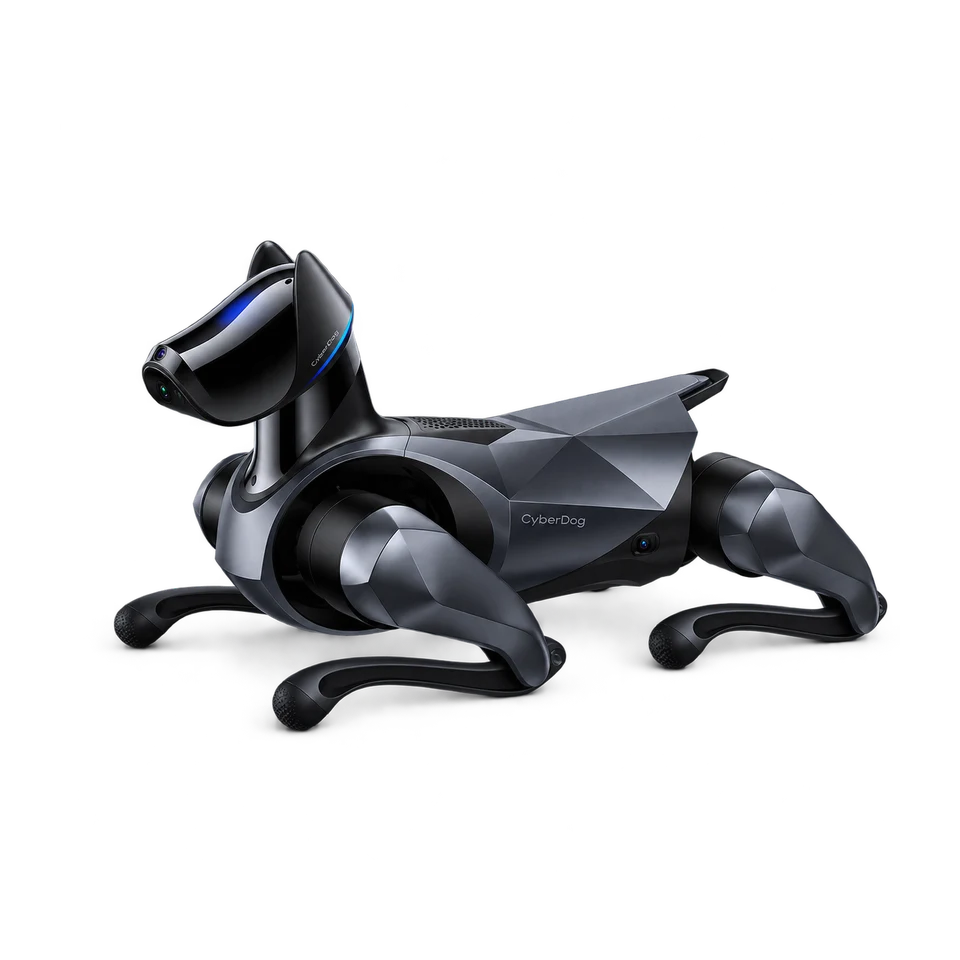
CyberDog 2
Second-generation dog-shaped quadruped with 12 actuated joints, multimodal sensing and a developer platform. The official Chinese site offers an F-code purchase channel; general regional availability is unconfirmed.
- Form
- quadruped
- Purpose
- Companionship & robotics development
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Compute | ||
| GPU | 384-core NVIDIA Volta GPU with 48 Tensor Cores | 2026-10-27 |
| Memory | 8GB LPDDR4x; 16GB eMMC; 32GB industrial SD | 2026-10-27 |
| Processor | Six-core NVIDIA Carmel ARM v8.2 64-bit CPU | 2026-10-27 |
| Configuration | ||
| Included controller | Bluetooth joystick remote with UWB tag positioning | 2026-10-27 |
| Model number | MS2242CN | 2026-10-27 |
| Connectivity | ||
| External interface | One USB Type-C port | 2026-10-27 |
| Wireless | Wi-Fi 802.11 a/b/g/n/ac; Bluetooth 5.0 | 2026-10-27 |
| Development | ||
| Operating system | Ubuntu 18.04 + ROS2 | 2026-10-27 |
| Environment | ||
| Operating temperature | 0–40°C | 2026-10-27 |
| Mobility | ||
| Degrees of freedom | 12 total; 3 per leg | 2026-10-27 |
| Maximum forward speed | 1.6 m/s, laboratory result | 2026-10-27 |
| Maximum payload | 1 kg | 2026-10-27 |
| Physical | ||
| Crouching dimensions | 603 × 339 × 300 mm | 2026-10-27 |
| Mass with battery | 8.9 ± 0.5 kg | 2026-10-27 |
| Standing dimensions | 562 × 339 × 481 mm | 2026-10-27 |
| Power | ||
| Battery | 21.6 V; 4,500 mAh; 97.2 Wh | 2026-10-27 |
| Charging time | About 90 minutes, laboratory result | 2026-10-27 |
| Power adaptor | MDY-13-EU: 100–240 V AC, 50/60 Hz, 3 A input; up to 20 V DC, 10.5 A output | 2026-10-27 |
| Runtime | About 90 minutes across resting, standing, static poses and ordinary walking in laboratory tests | 2026-10-27 |
| Purchase | ||
| Availability and region | China product page lists F-code access and customer service; open stock and international delivery are not confirmed. | 2026-10-27 |
| Pricing basis | No current applicable USD price verified; consult Xiaomi’s China sales channel for price and access. | 2026-10-27 |
| Sensors | ||
| Additional sensors | Touch, ultrasonic, ToF, microphone, UWB and IMU | 2026-10-27 |
| Cameras | RealSense D430 depth, 13MP interaction, 1MP RGB, 146° fisheye | 2026-10-27 |
| Laser sensor | YDLIDAR TG30 | 2026-10-27 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | 1 | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Travel speed Travel speed · manufacturer claimXiaomi reports a maximum forward speed of 1.6 m/s under laboratory conditions. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-27 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.