 Pollen Robotics
Microduck
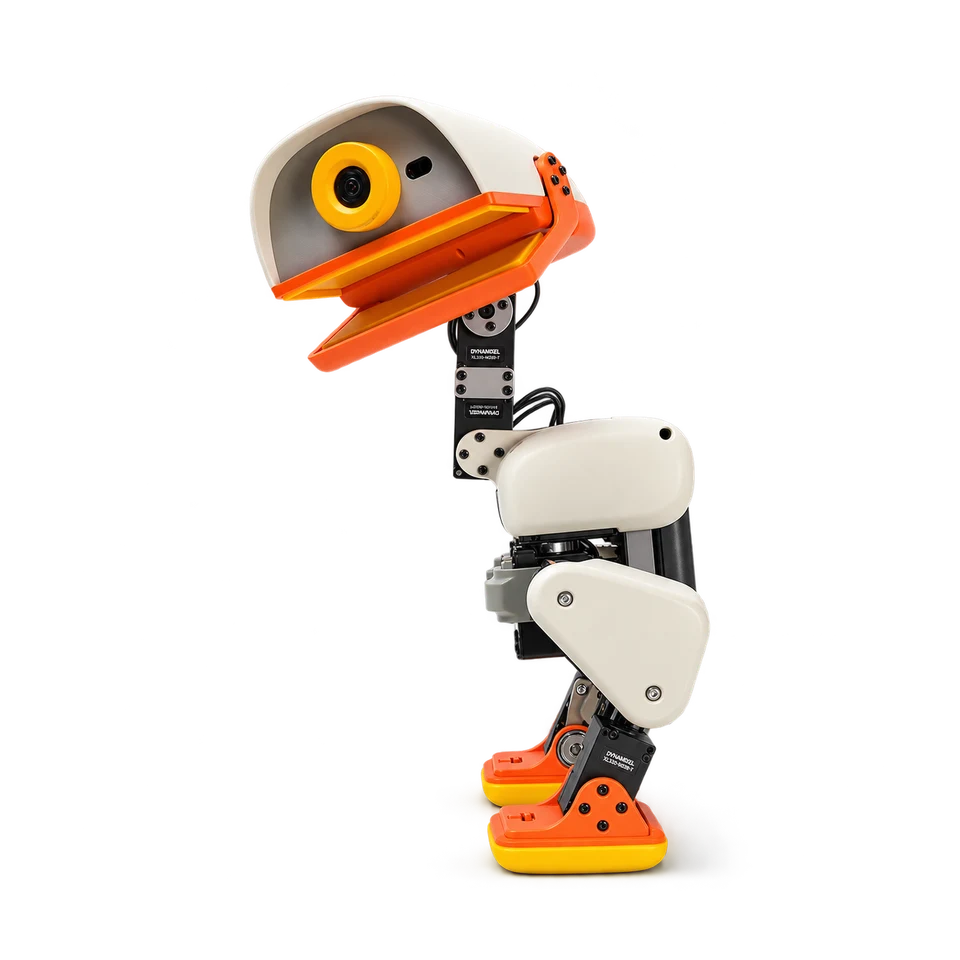
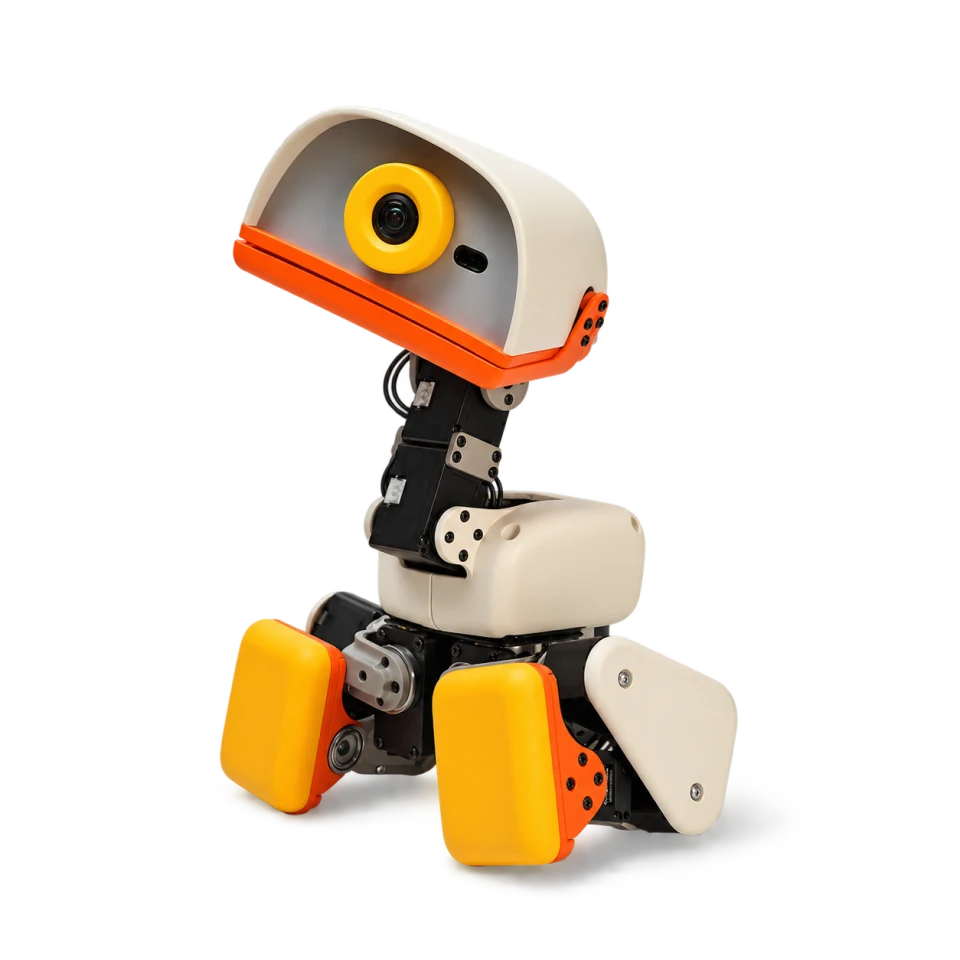
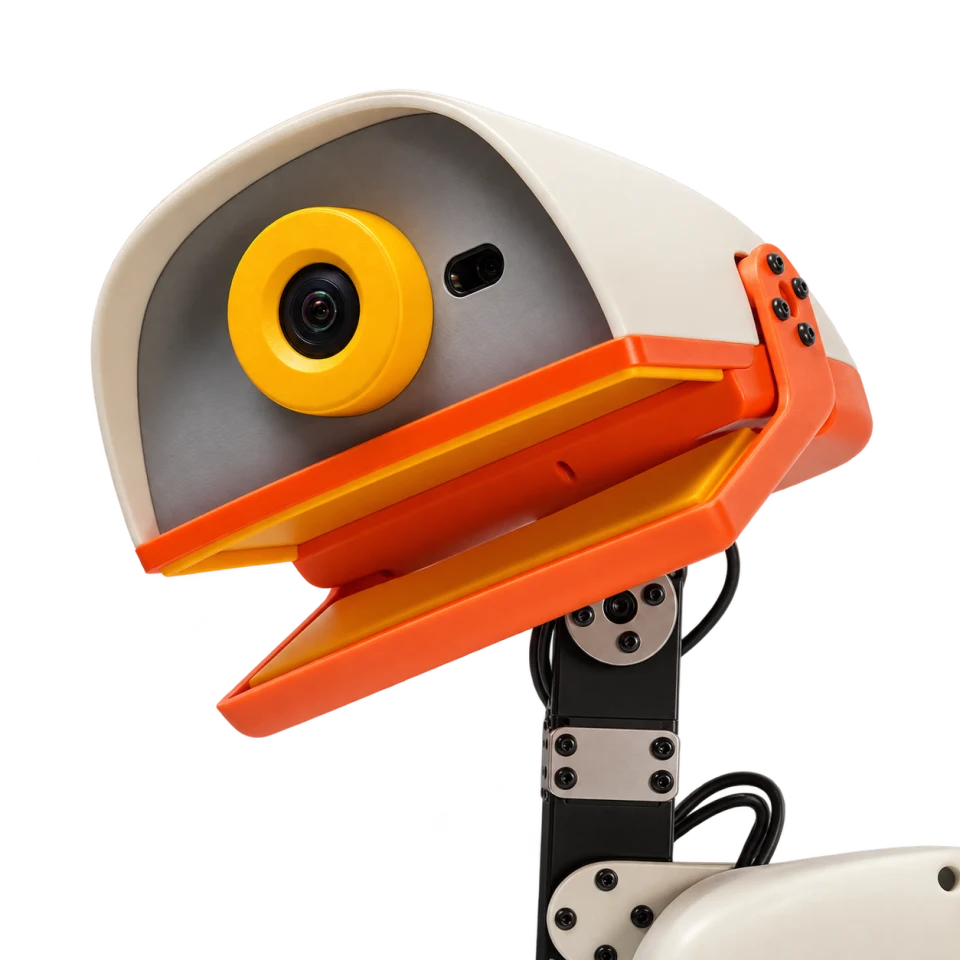
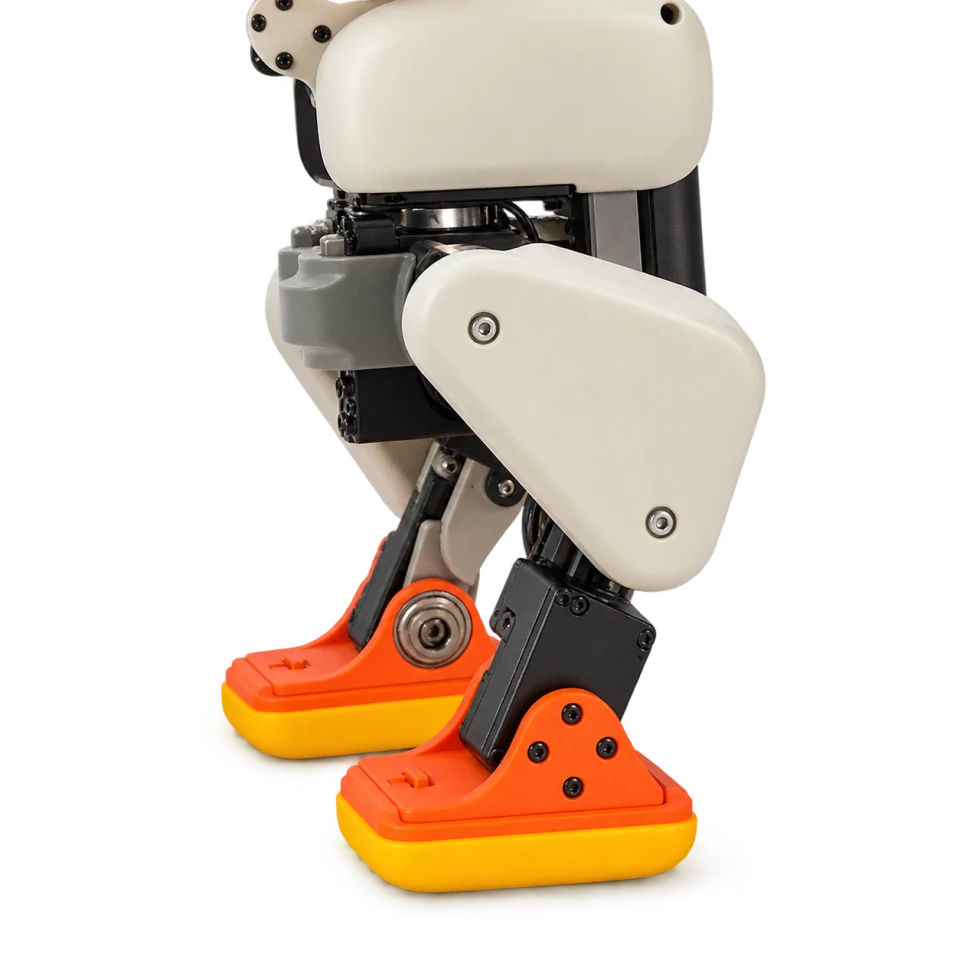
Small programmable biped with a grasping beak, gamepad control and trainable movements. Software is open source; hardware design files are not. Cream artwork represents one of four colourways.
- Form
- companion
- Purpose
- Biped learning & creative coding
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Compute | ||
| Memory and storage | 1 GB RAM; 32 GB storage | 2026-10-28 |
| Processor | Rockchip RK3566 with AI accelerator | 2026-10-28 |
| Configuration | ||
| Colourways | Cream, Graphite, Lavender, Sky; same underlying robot | 2026-10-28 |
| Included equipment | Robot, battery, USB-C cable and game controller | 2026-10-28 |
| Connectivity | ||
| Wireless | Wi-Fi and Bluetooth; radio versions provisional | 2026-10-28 |
| Development | ||
| Policy loop | 50 Hz onboard | 2026-10-28 |
| Simulation | MuJoCo training and sim-to-real deployment | 2026-10-28 |
| Software access | Open-source SDK and RL training stack; mechanical/electronic design files excluded | 2026-10-28 |
| Interaction | ||
| Audio | Microphones and speaker | 2026-10-28 |
| NFC | Two antennas: head and beak | 2026-10-28 |
| Manipulation | ||
| Gripper | Articulated grasping beak | 2026-10-28 |
| Mobility | ||
| Actuation | 15 motors / degrees of freedom | 2026-10-28 |
| Physical | ||
| Dimensions | 25 cm tall × 14 cm wide | 2026-10-28 |
| Mass | 780 g in the store; press sheet says under 800 g | 2026-10-28 |
| Power | ||
| Battery | Removable NP-F550, 2600 mAh | 2026-10-28 |
| Runtime | Around one hour, depending on use | 2026-10-28 |
| Purchase | ||
| Availability and region | Preorder; launch markets: US, Canada, EU, UK, Norway, Switzerland, Japan and South Korea | 2026-10-28 |
| Delivery target | Before Christmas 2026; manufacturer target | 2026-10-28 |
| Pricing basis | Introductory preorder price US$399, excluding taxes and shipping. | 2026-10-28 |
| Sensors | ||
| Camera | Front camera with camera-use indicator; resolution and field of view provisional | 2026-10-28 |
| Inertial sensing | Two IMUs: body and head | 2026-10-28 |
| Range sensing | 8 × 8 time-of-flight LiDAR matrix; range provisional | 2026-10-28 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | 1 | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Unfamiliar-object grasping Unfamiliar-object grasping · manufacturer claimPollen describes picking up objects with the articulated beak using learned movements; no independent grasping benchmark is supplied. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-28 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.