Maker profile
AgileX Robotics
AgileX Robotics builds mobile platforms and manipulators for robotics development. Its range includes wheeled and tracked research bases, educational robots, and arm systems for manipulation and teleoperation.
Sources & checked dates
Overview based on manufacturer product documentation. Product claims are not independent test results.
- SCOUT MINIChecked
- SCOUT 2.0Checked
- BUNKER MINI 2.0Checked
- PiPERChecked
- HUNTER SEChecked
- RANGER MINI 3.0Checked
- LIMO PROChecked
- COBOT MAGIC (TRACER 2.0)Checked
- LIMO COBOTChecked
Robot lineup
Explore AgileX Robotics robots, their specifications, availability, and evidence.
AgileX Robotics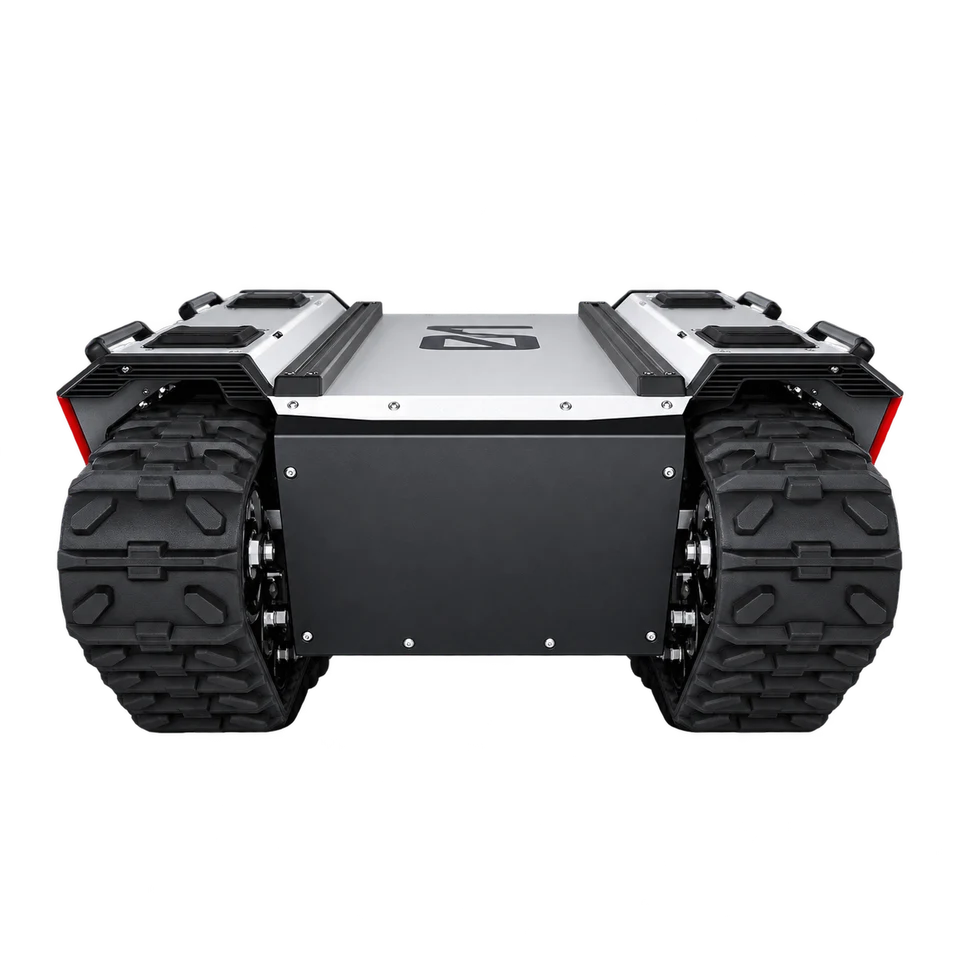
field
BUNKER MINI 2.0
Price unknownConfigurable tracked base. Autonomous navigation requires added sensors, compute and software.
AgileX Robotics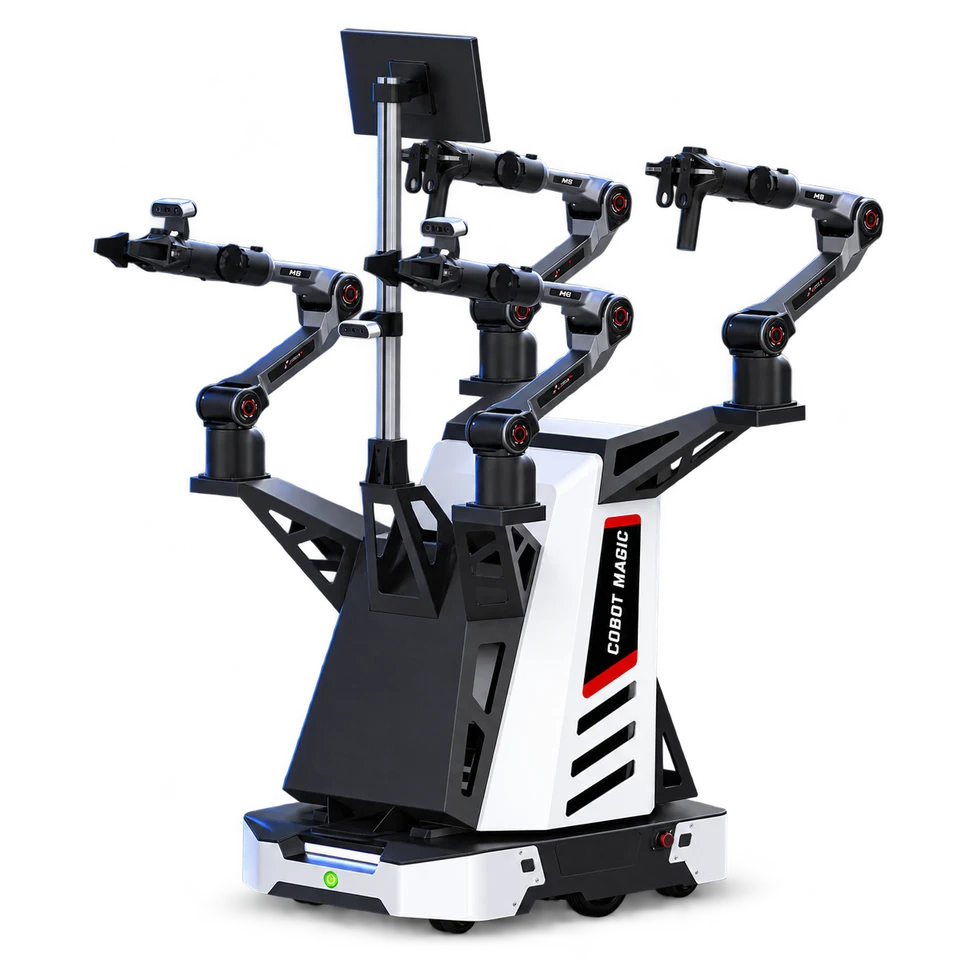
mobile manipulator
COBOT MAGIC (TRACER 2.0)
Price unknownMobile ALOHA-based research system combining a mobile base with leader/follower arms and cameras for demonstration collection. This entry follows the current TRACER 2.0 configuration.
AgileX Robotics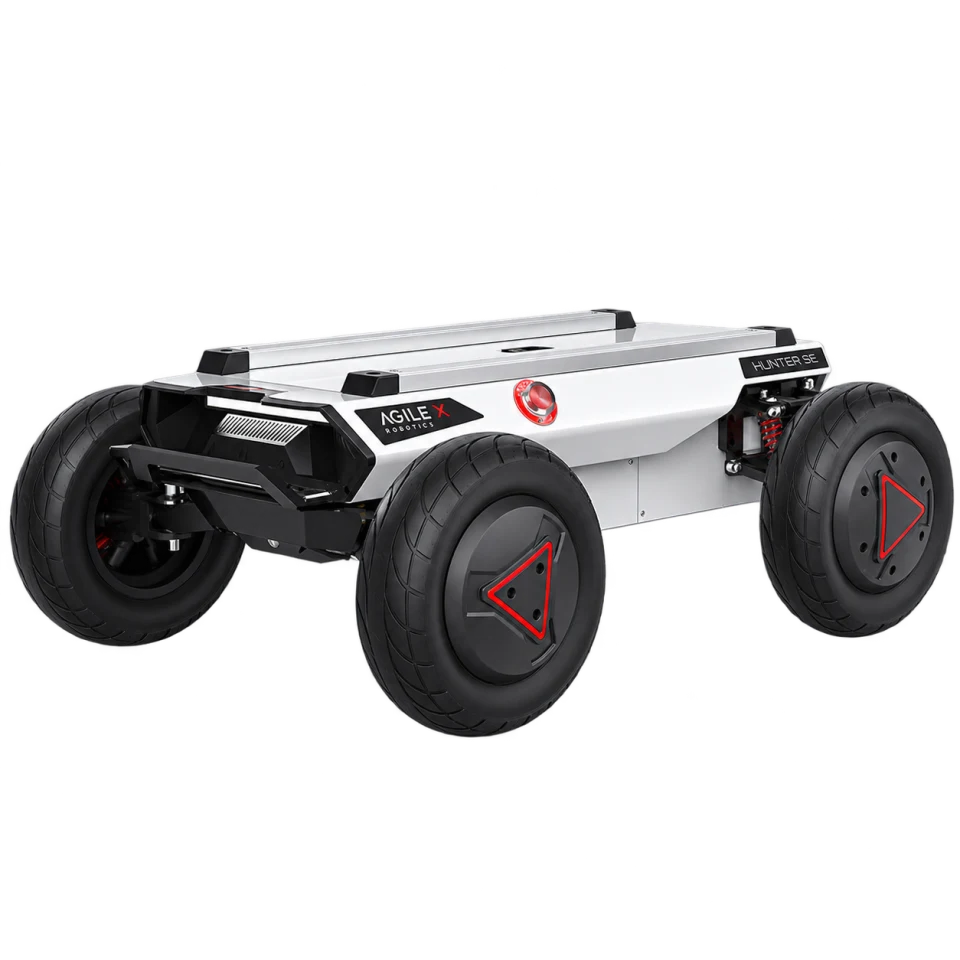
field
HUNTER SE
Price unknownFour-wheel Ackermann platform for mobile robotics integration. Payload, sensors and autonomy software require project-specific configuration.
AgileX Robotics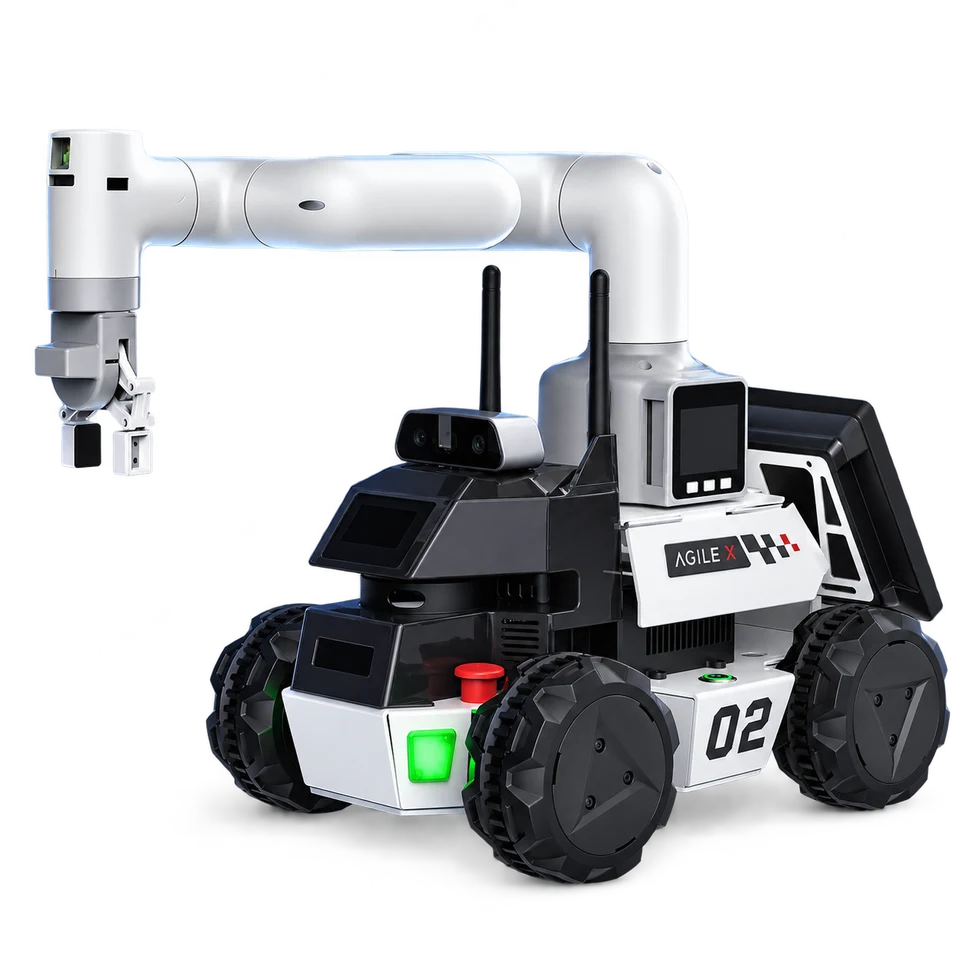
mobile manipulator
LIMO COBOT
Price unknownCompact ROS teaching platform with a six-axis arm, Orin Nano computer and depth perception for navigation-and-grasping development.
AgileX Robotics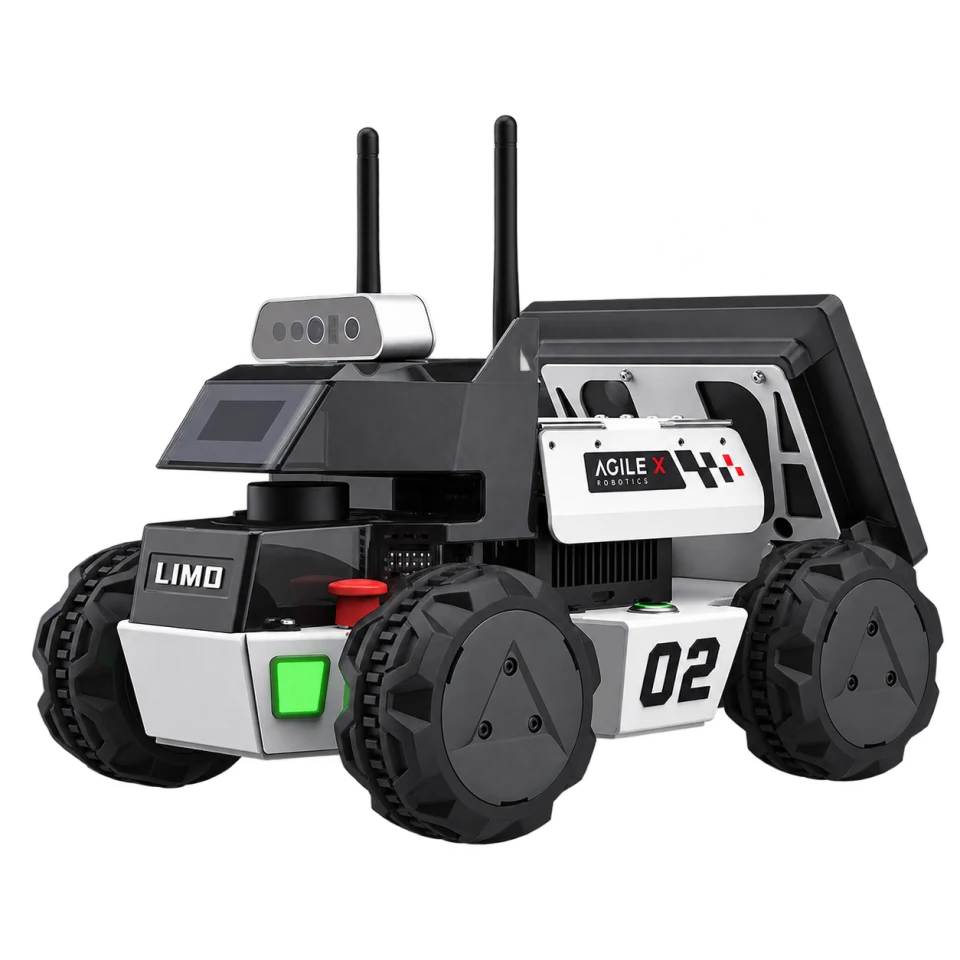
field
LIMO PRO
Price unknownReconfigurable mobile learning platform with Jetson compute, depth camera and LiDAR. The standard PRO configuration has no robotic arm.
AgileX Robotics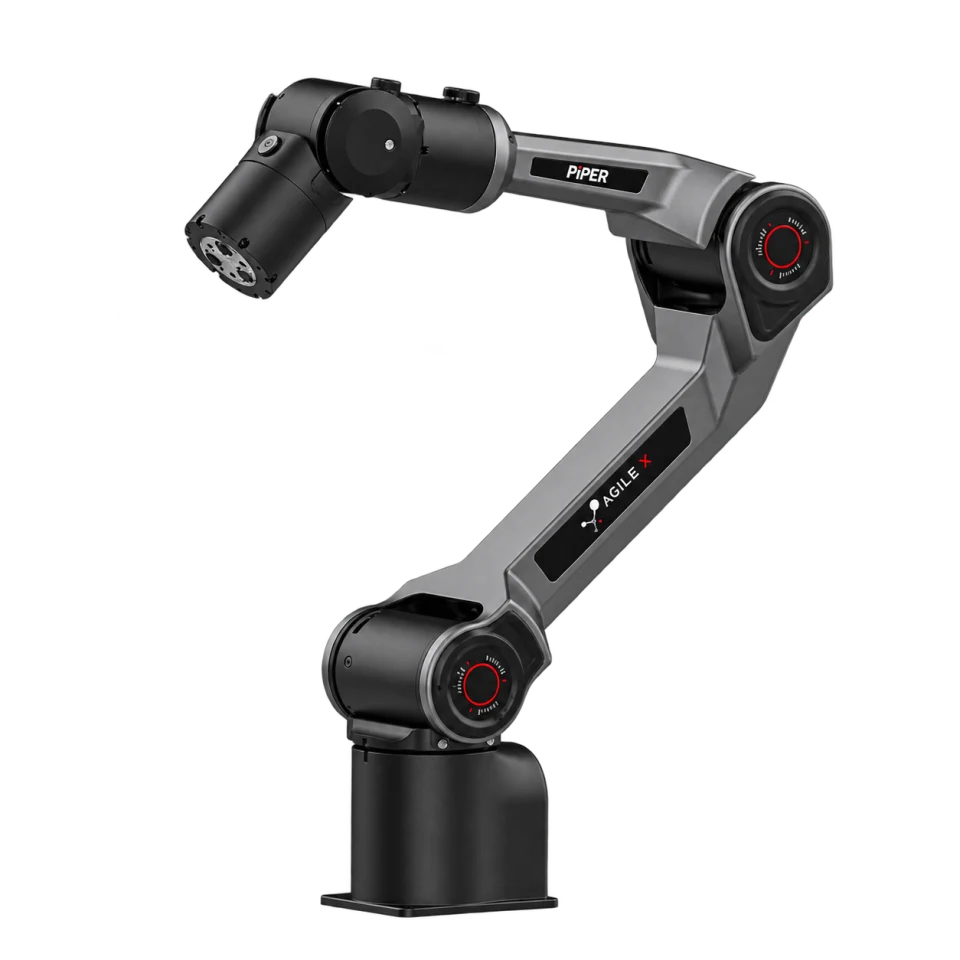
arm
PiPER
Price unknownLightweight six-axis arm with CAN control, drag teaching and ROS development resources. This record covers PiPER, not PiPER-X.
AgileX Robotics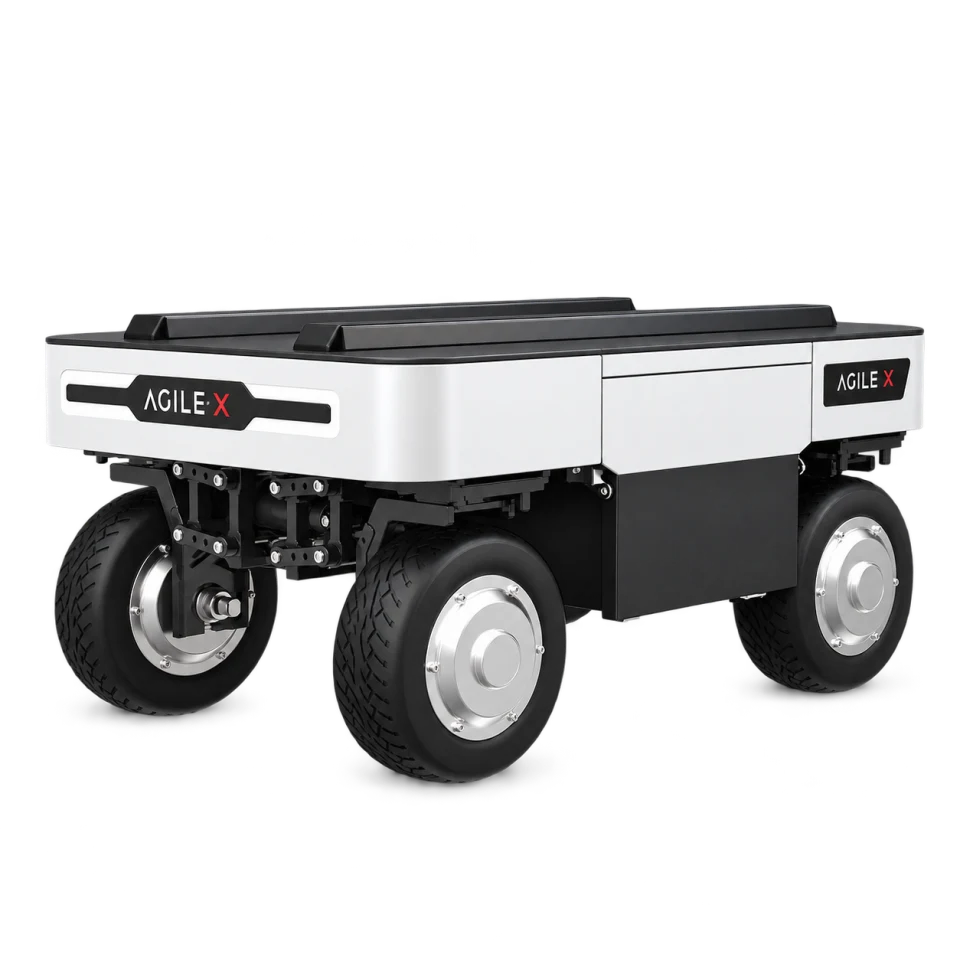
field
RANGER MINI 3.0
Price unknownFour-wheel drive and steering platform with a 120 kg advertised payload. Specifications follow the RANGER MINI 3.0 table.
AgileX Robotics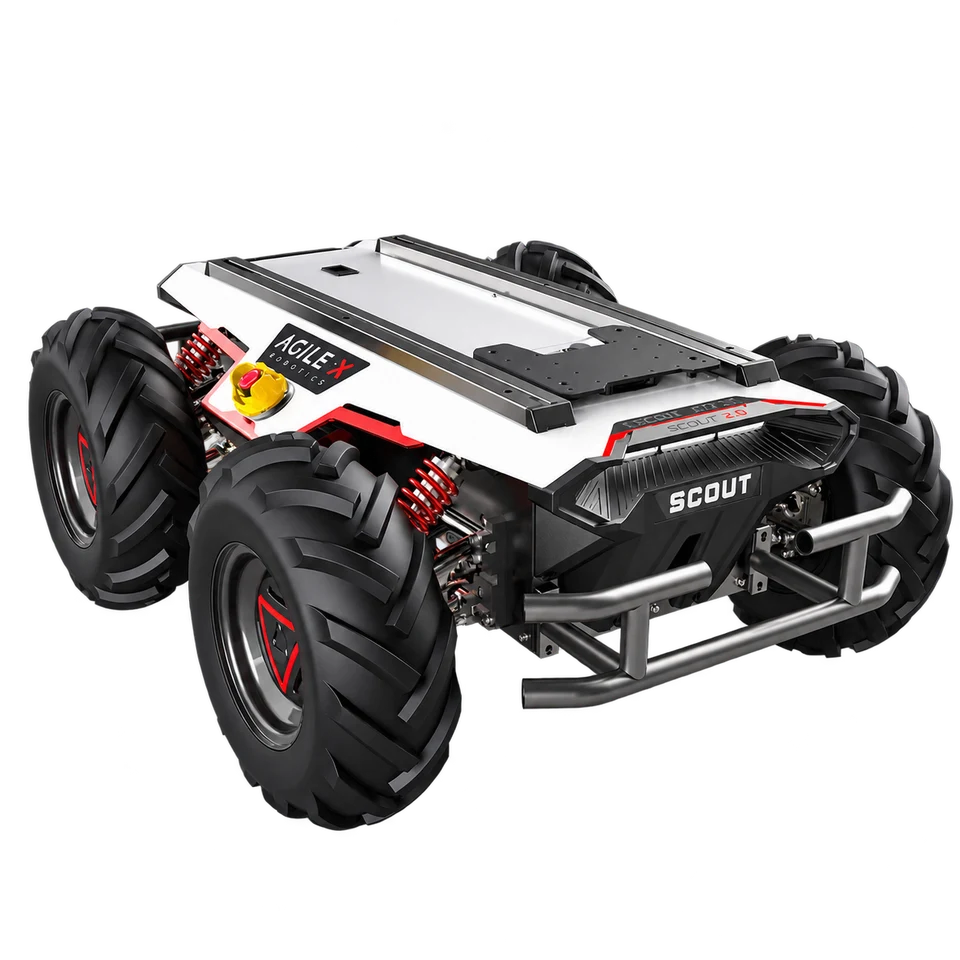
field
SCOUT 2.0
Price unknownConfigurable differential-drive base. Autonomous navigation requires added sensors, compute and software.
AgileX Robotics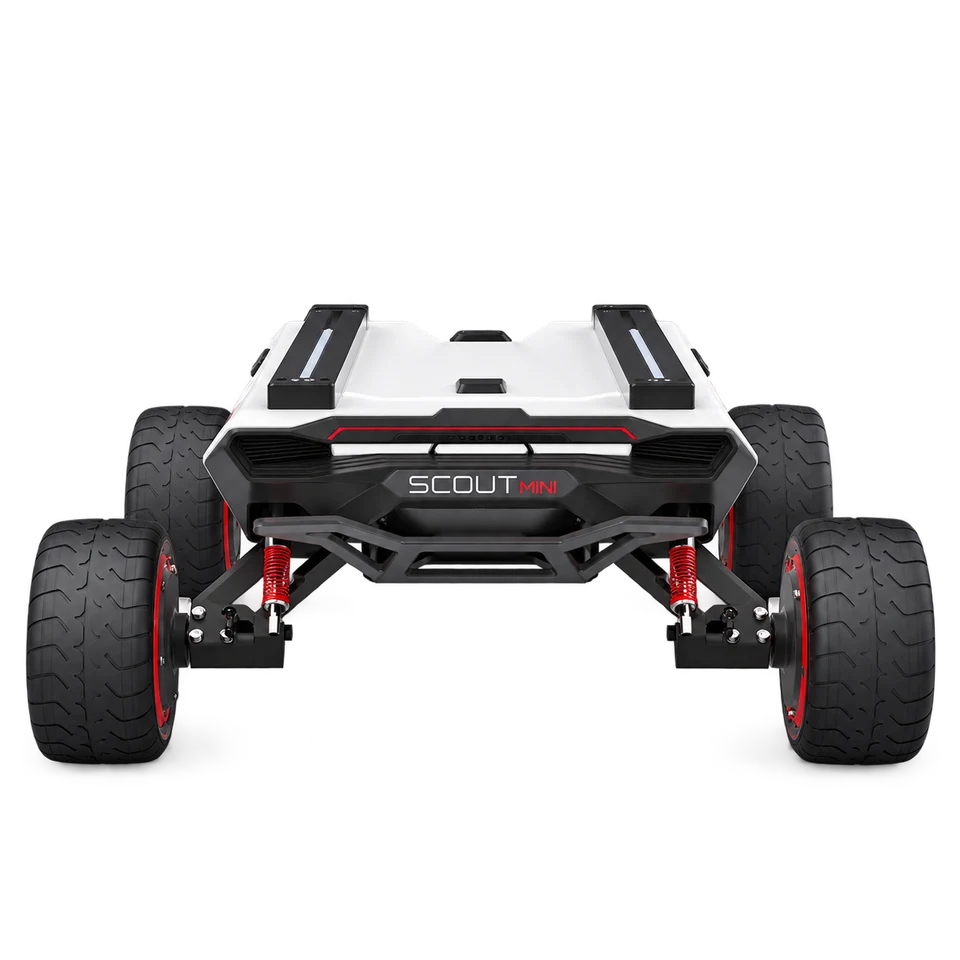
field
SCOUT MINI
Price unknownConfigurable differential-drive base. Autonomous navigation requires added sensors, compute and software.