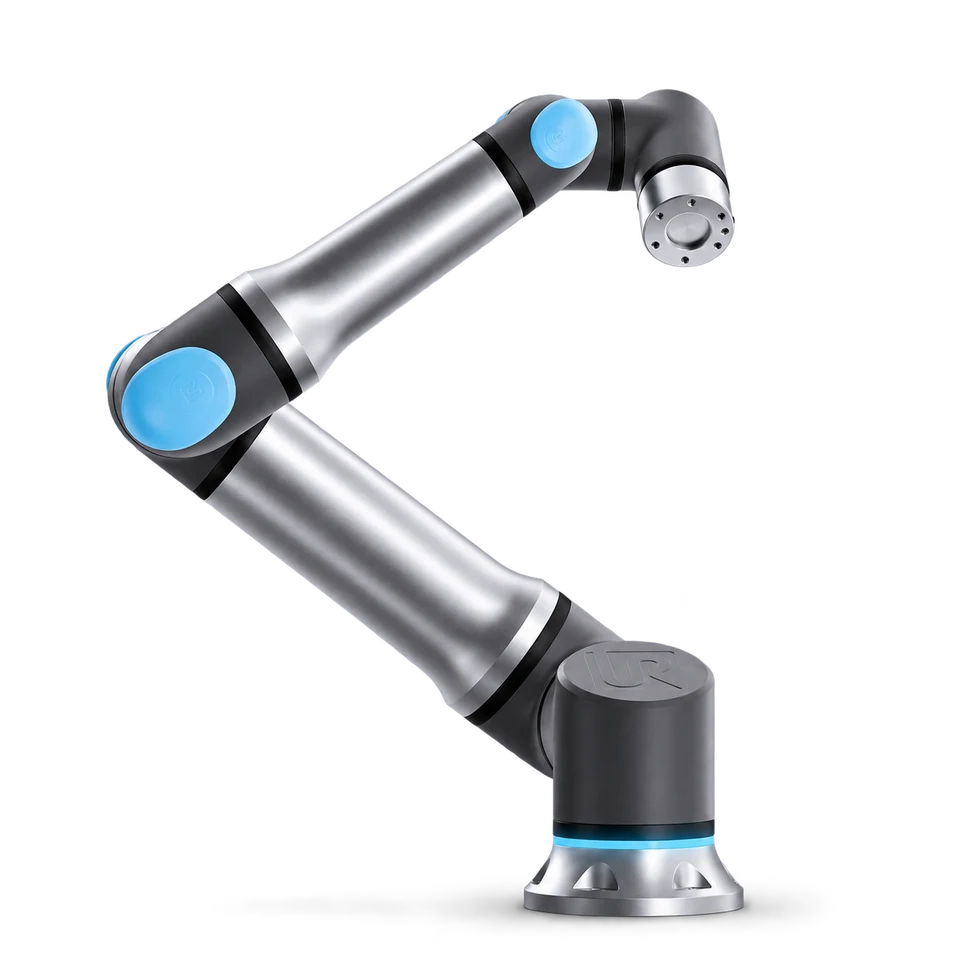
 Universal Robots
UR30-1300
Industrial arm with 1300 mm reach. Extended payload requires confirmation of the applicable load envelope.
- Form
- arm
- Purpose
- Industrial automation
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Configuration | ||
| Tool mechanical interface | ISO 9409-1-50-4-M6 | 2026-10-26 |
| Connectivity | ||
| Tool connector | M8 8-pin female; two digital I/O, two analogue inputs or RS-485 | 2026-10-26 |
| Interaction | ||
| Status indication | Programmable base LED light ring | 2026-10-26 |
| Manipulation | ||
| Maximum TCP speed | 4 m/s; tool speed, not travel speed | 2026-10-26 |
| Payload | 30 kg nominal; up to 35 kg extended payload; confirm load envelope | 2026-10-26 |
| Pose repeatability | ±0.01 mm; manufacturer product table | 2026-10-26 |
| Reach | 1300 mm | 2026-10-26 |
| Physical | ||
| Arm mass | 63.5 kg | 2026-10-26 |
| Footprint | Ø245 mm | 2026-10-26 |
| Power | ||
| Tool power | 12 V or 24 V | 2026-10-26 |
| Protection | ||
| Arm ingress rating | IP65 | 2026-10-26 |
| Purchase | ||
| Availability and region | Official sales enquiry route; confirm regional supply, tooling, installation and lead time. | 2026-10-26 |
| Pricing basis | Manufacturer sales quote; end effector, integration and regional terms are configuration-dependent. No public configured USD price verified. | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | 1 | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Fine manipulation Fine manipulation · manufacturer claimUniversal Robots reports pose repeatability of ±0.01 mm; repeatability is not absolute positioning accuracy or independent task success. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.