 UBTECH
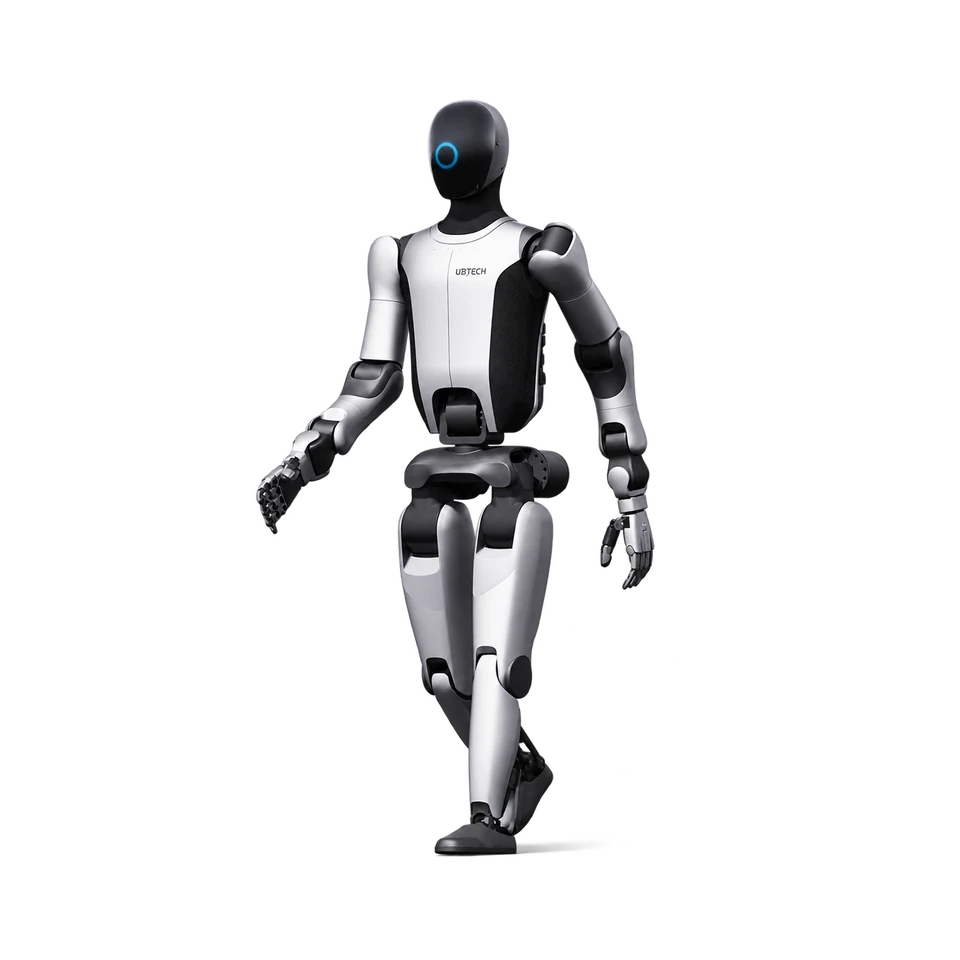
Walker S2
Industrial humanoid with dexterous hands and a dual-battery system designed for autonomous battery replacement.
- Form
- humanoid
- Purpose
- Industrial humanoid manipulation
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Actuation | ||
| Degrees of freedom | 52 | 2026-10-26 |
| Waist motion | Rotation ±162°; pitch +90° to −35° | 2026-10-26 |
| Connectivity | ||
| Interfaces | Gigabit Ethernet and USB 3.0 | 2026-10-26 |
| Interaction | ||
| Facial display | 4-inch circular display | 2026-10-26 |
| Manipulation | ||
| Finger grasp | 1 kg | 2026-10-26 |
| Hand configuration | 11 DOF and 6 tactile-sensor arrays | 2026-10-26 |
| Single-hand grasp | 7.5 kg | 2026-10-26 |
| Whole-body payload | 15 kg across a stated 0–1.8 m working height | 2026-10-26 |
| Mobility | ||
| Walking speed | 2 m/s | 2026-10-26 |
| Physical | ||
| Height | 176 cm | 2026-10-26 |
| Mass | 70 kg | 2026-10-26 |
| Power | ||
| Battery system | Dual batteries; autonomous swapping advertised within 3 minutes | 2026-10-26 |
| Purchase | ||
| Availability and region | Industrial sales enquiry through UBTECH; delivery region, deployment terms and configuration require confirmation. | 2026-10-26 |
| Pricing basis | No configured USD price confirmed in the reviewed manufacturer source; request current package pricing. | 2026-10-26 |
| Sensors | ||
| Vision | 2 fisheye cameras, 2 RGB cameras and front/rear RGB-D cameras | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | 1 | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Load carrying Load carrying · manufacturer claimUBTECH specifies a 15 kg carrying capacity across a 0–1.8 m working height; its separate single-hand grasp figure is 7.5 kg. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
Safety
No model-wide certification is asserted by Omblet. Read the safety disclosure on each evidence record and the manufacturer documentation.
Cybersecurity
No model-wide certification is asserted by Omblet. Read the cybersecurity disclosure on each evidence record and the manufacturer documentation.
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.