 ROBOTIS
AI Worker FFW-SG2
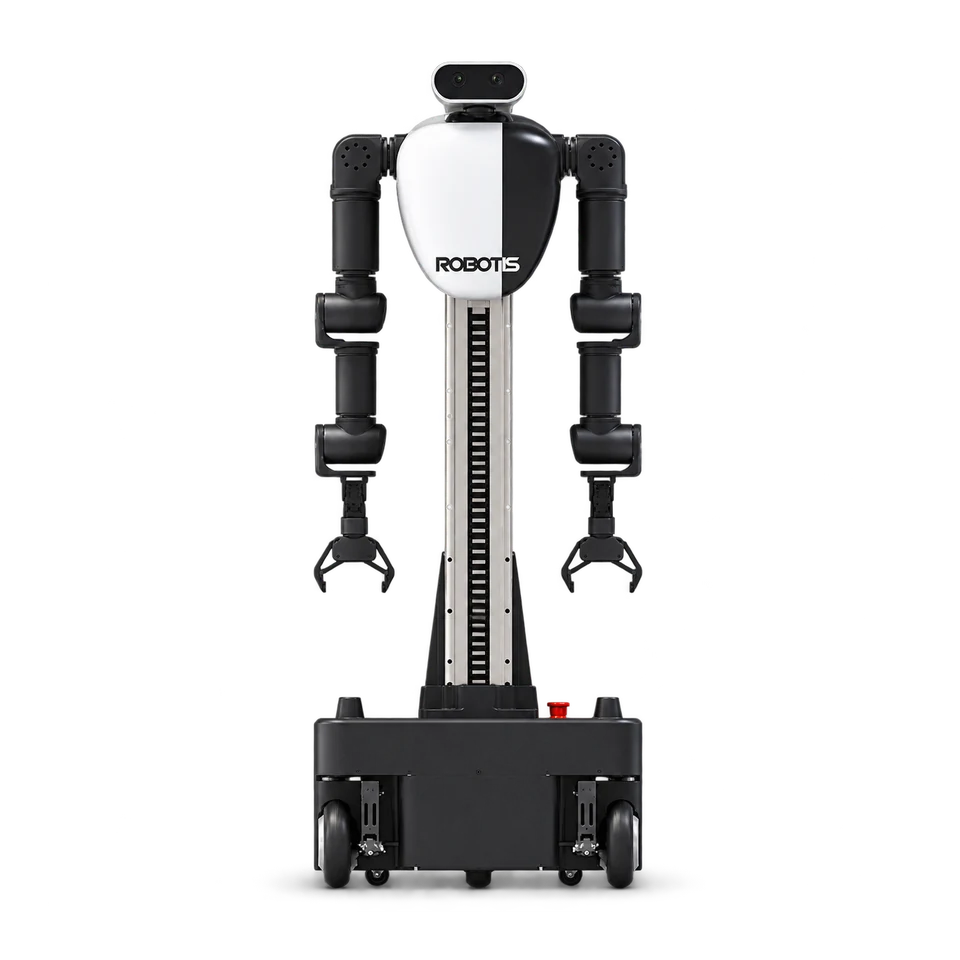
Mobile follower platform with two seven-axis arms, standard two-finger grippers and a swerve-drive base. This record covers the battery-powered FFW-SG2, not the stationary BG2 or wearable leader.
- Form
- mobile manipulator
- Purpose
- Mobile imitation-learning research
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Compute | ||
| Computer | NVIDIA Jetson AGX Orin 32GB | 2026-10-26 |
| Environment | ||
| Operating temperature | 0–40°C | 2026-10-26 |
| Manipulation | ||
| Arm reach | 641 mm to wrist, plus hand | 2026-10-26 |
| Nominal payload | 3 kg per arm; 6 kg with both arms | 2026-10-26 |
| Peak payload | 5 kg per arm; 10 kg with both arms; posture and motion dependent | 2026-10-26 |
| Standard grippers | RH-P12-RN two-finger grippers | 2026-10-26 |
| Mobility | ||
| Drive | Swerve drive; 1.5 m/s operating velocity | 2026-10-26 |
| Motion | ||
| Degrees of freedom | 25 total; two 7-DoF arms, two 1-DoF grippers, 2-DoF head, 1-DoF lift and 6 mobile DoF | 2026-10-26 |
| Physical | ||
| Dimensions | 604 × 602 × 1623 mm (W × D × H) | 2026-10-26 |
| Mass | 90 kg | 2026-10-26 |
| Power | ||
| Battery | 25 V, 80 Ah; manufacturer lists 2040 Wh | 2026-10-26 |
| Purchase | ||
| Availability and region | Made to order through ROBOTIS US; standard eight-week lead time stated, ships from Korea. Confirm regional terms. | 2026-10-26 |
| Pricing basis | No verified public USD price for this configuration; request a manufacturer or authorized-dealer quotation. | 2026-10-26 |
| Sensors | ||
| Sensor suite | Three RGB-D cameras, two LiDARs and IMU | 2026-10-26 |
| Software | ||
| Development | ROS 2, Python, C++ and Web UI | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | 1 | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Unfamiliar-object grasping Unfamiliar-object grasping · manufacturer claimROBOTIS supplies dual seven-axis arms with adaptive two-finger grippers for manipulation research; autonomous task performance depends on the trained policy. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.