 Mobile Industrial Robots
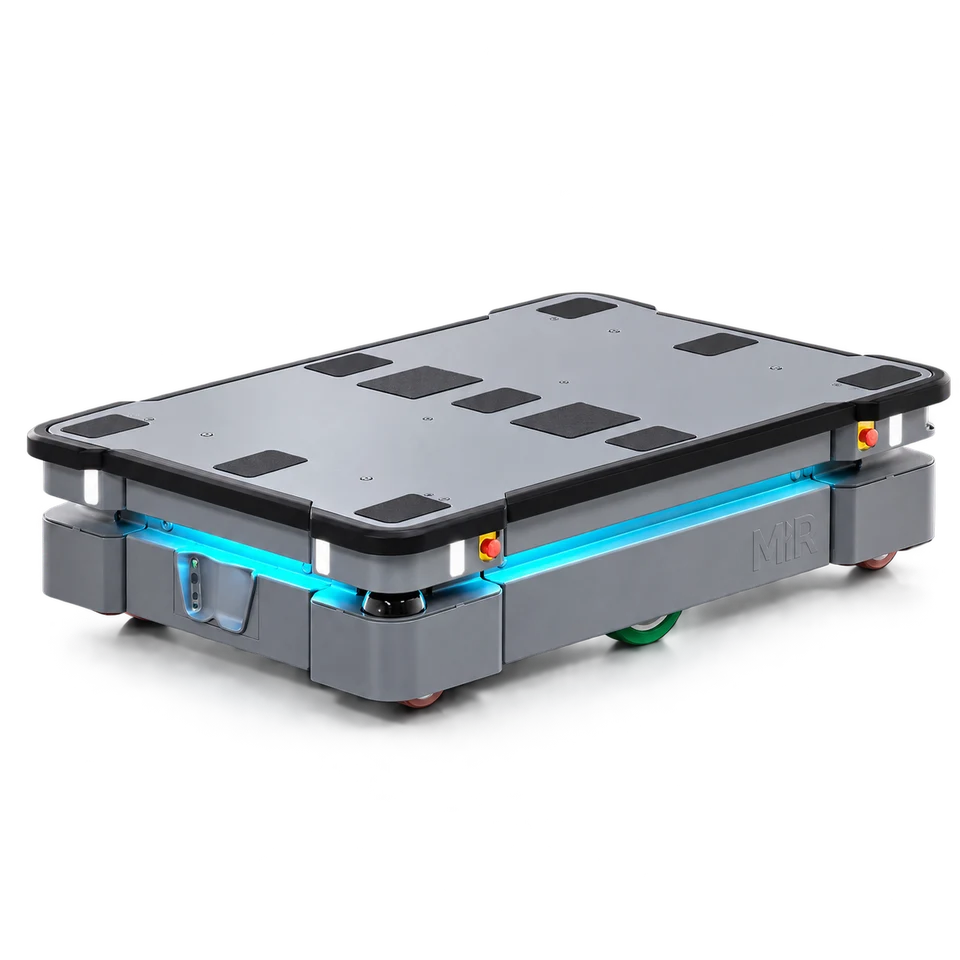
MiR600
Autonomous indoor transport base rated for 600 kg. Top modules and site integration are application-specific; runtime varies with payload.
- Form
- field
- Purpose
- Indoor material transport
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Configuration | ||
| Load surface | 1,304 × 864 mm | 2026-10-26 |
| Specification conditions | Values vary with local conditions and application setup | 2026-10-26 |
| Mobility | ||
| Ground clearance | 25–27 mm | 2026-10-26 |
| Maximum payload | 600 kg | 2026-10-26 |
| Maximum speed | 2.0 m/s | 2026-10-26 |
| Physical | ||
| Dimensions | 1,350 × 910 × 322 mm | 2026-10-26 |
| Mass | 240 kg | 2026-10-26 |
| Power | ||
| Battery | Lithium-ion | 2026-10-26 |
| Charging ratio | 10 minutes charging for up to 2 hours at maximum payload | 2026-10-26 |
| Loaded runtime | Up to 8 hours 30 minutes with maximum payload | 2026-10-26 |
| Unloaded runtime | Up to 11 hours | 2026-10-26 |
| Purchase | ||
| Availability and region | Manufacturer sales/demo route; regional delivery and application setup require confirmation. | 2026-10-26 |
| Pricing basis | Contact manufacturer sales for the robot, top module and installation quote; no configured public USD price verified. | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | 1 | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Load carrying Load carrying · manufacturer claimMiR rates MiR600 for 600 kg of payload; top modules, load geometry and site conditions affect the application. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.