 LuxAI
QTrobot RD-V3 AI@Edge
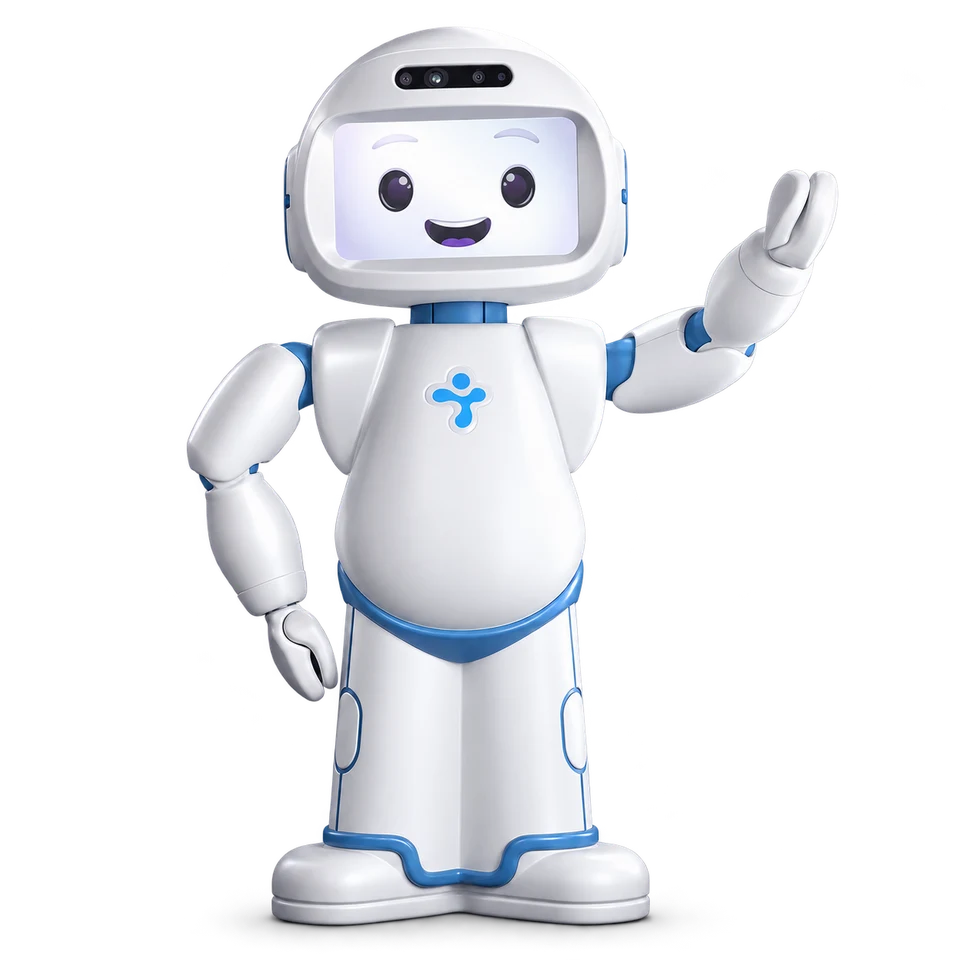
Stationary social humanoid with an expressive face and articulated upper body. The AI@Edge configuration combines Jetson AGX Orin with a Raspberry Pi and supports local AI workloads.
- Form
- humanoid
- Purpose
- Social interaction research
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Compute | ||
| GPU | 2,048 cores at 1.3 GHz | 2026-10-26 |
| Main computer | NVIDIA Jetson AGX Orin; 12-core Arm CPU at 2.2 GHz | 2026-10-26 |
| Memory and storage | 64 GB RAM and 2 TB NVMe | 2026-10-26 |
| Secondary computer | Raspberry Pi 4B; quad-core Arm at 1.8 GHz, 4 GB RAM and 64 GB eMMC | 2026-10-26 |
| Connectivity | ||
| Interfaces | USB 3 / USB-C and DisplayPort on Jetson; HDMI adaptor included; USB 3 on Raspberry Pi | 2026-10-26 |
| Development | ||
| Graphical programming | Offline Graphical Studio; GPL 3.0 | 2026-10-26 |
| Programming | Python, TypeScript/Node.js and ROS 2 | 2026-10-26 |
| Speech integration | Offline Parakeet and Qwen3-TTS options; some other speech services require separate licences | 2026-10-26 |
| Interaction | ||
| Audio output | Stereo 2.8 W Class D | 2026-10-26 |
| Microphone array | ReSpeaker Mic Array v2.0 | 2026-10-26 |
| Purchase | ||
| Availability and region | Research purchase/quote route; confirm destination and lead time with LuxAI. | 2026-10-26 |
| Pricing basis | US$19,900 for RD-V3 AI@Edge; listed with two-year warranty and free shipping. Confirm taxes, destination and optional software licences. | 2026-10-26 |
| Sensors | ||
| Depth camera | Intel RealSense D455 | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | 1 | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Instruction following Instruction following · manufacturer claimLuxAI advertises programmable spoken interaction and expressive upper-body gestures; this is a manufacturer description, not measured task performance. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.