 eufy
Omni S1 Pro
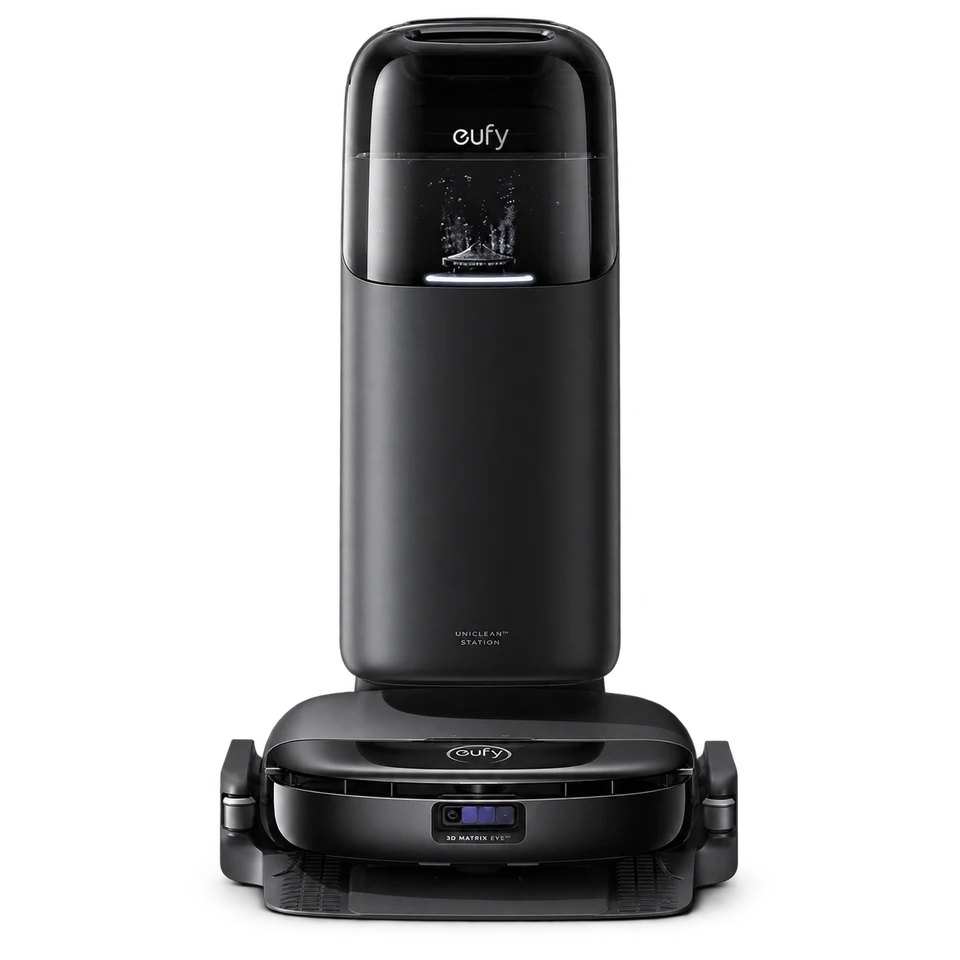
Floor-cleaning robot with a self-refreshing roller mop, binocular infrared obstacle sensing and a maintenance station.
- Form
- household
- Purpose
- Vacuuming and floor washing
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Cleaning | ||
| Maximum suction | 8,000 Pa; manufacturer rating | 2026-10-26 |
| Mop lift | 0.5 in on carpet detection | 2026-10-26 |
| Mop loading | 1 kg advertised downward loading | 2026-10-26 |
| Mop system | HydroJet rotating roller with continuous onboard washing | 2026-10-26 |
| Roller length | 11.4 in | 2026-10-26 |
| Dock | ||
| Maintenance | Dust emptying, mop washing, heated drying, water refill and detergent dispensing | 2026-10-26 |
| Interaction | ||
| App features | Schedules, cleaning modes, resume and no-go zones | 2026-10-26 |
| Station controls | LCD touch control | 2026-10-26 |
| Navigation | ||
| Mapping | dToF LiDAR with 3D SLAM; app displays 2D maps | 2026-10-26 |
| Physical | ||
| Robot dimensions | 12.8 × 13.7 × 3.8 in | 2026-10-26 |
| Purchase | ||
| Availability and region | Official product/store route; confirm destination, selected bundle and current stock. | 2026-10-26 |
| Pricing basis | Official product page reviewed; no unambiguous current USD package price verified. Confirm price, included accessories and regional stock. | 2026-10-26 |
| Sensors | ||
| Obstacle sensing | Active binocular infrared, 3D MatrixEye | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | No records | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | 1 | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Obstacle avoidance Obstacle avoidance · manufacturer claimeufy advertises binocular infrared obstacle avoidance; its internal tests and low-light limitations do not establish universal detection. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.