 DJI
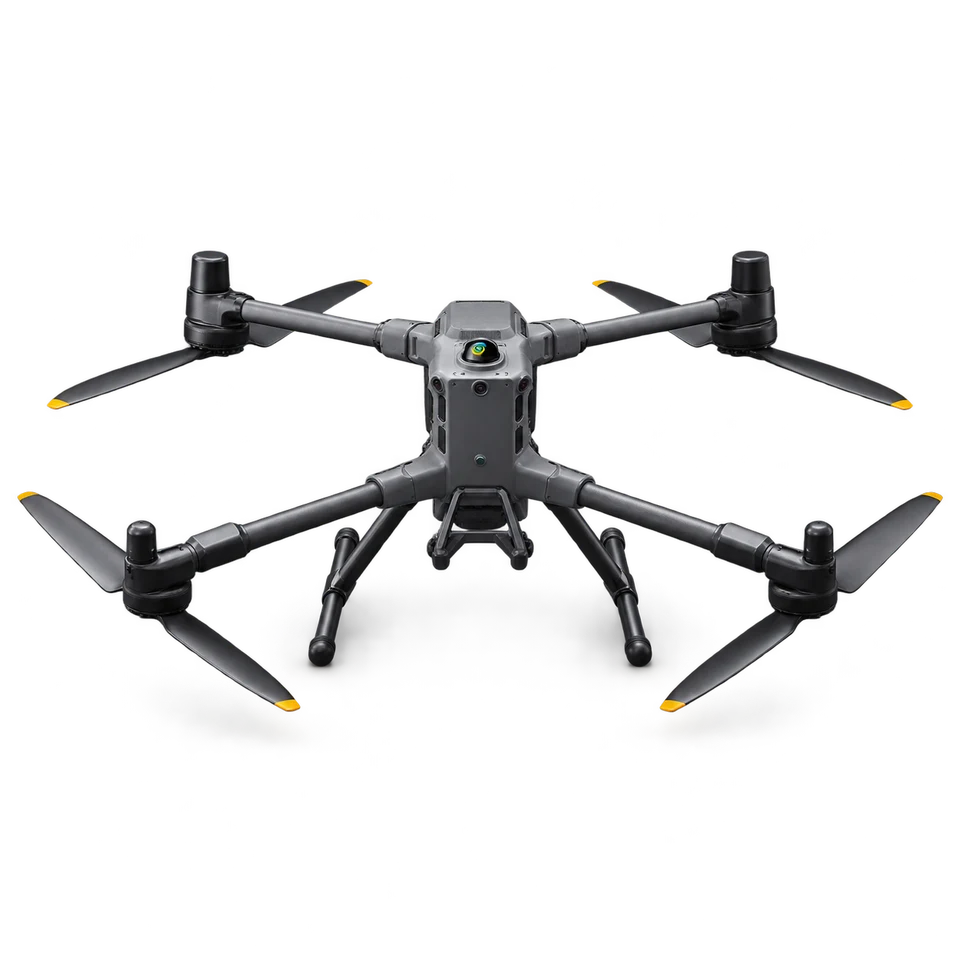
Matrice 400
Enterprise multirotor with modular payload connectors. The 59-minute flight figure uses an H30T payload, not the maximum 6 kg load.
- Form
- drone
- Purpose
- Aerial imaging and inspection
Specifications
Manufacturer-reported hardware and purchase details. Configuration differences stay with each value.
| Attribute | Reported value | Source |
|---|---|---|
| Environment | ||
| Temperature | −20–50°C without solar radiation | 2026-10-26 |
| Wind resistance | 12 m/s during takeoff and landing | 2026-10-26 |
| Manipulation | ||
| Maximum payload | 6 kg at third gimbal connector, sea level; decreases with altitude | 2026-10-26 |
| Mobility | ||
| Maximum ascent / descent | 10 / 8 m/s | 2026-10-26 |
| Maximum horizontal speed | 25 m/s, windless sea level | 2026-10-26 |
| Physical | ||
| Aircraft mass | 9,740 ±40 g with batteries and propellers | 2026-10-26 |
| Diagonal wheelbase | 1,070 mm | 2026-10-26 |
| Maximum takeoff mass | 15.8 kg | 2026-10-26 |
| Propeller diameter | 25 inches | 2026-10-26 |
| Unfolded dimensions | 980 × 760 × 480 mm with landing gear; excludes propellers | 2026-10-26 |
| Power | ||
| Maximum flight time | 59 minutes at 10 m/s, windless sea level, H30T only, 10,670 g total, to depletion | 2026-10-26 |
| Maximum hover time | 53 minutes; H30T only, windless sea level, 100% to 0% | 2026-10-26 |
| Purchase | ||
| Availability and region | Manufacturer product/sales route; confirm regional stock and exact aircraft package. | 2026-10-26 |
| Pricing basis | No applicable configured USD price verified; confirm the aircraft, controller, batteries, service plan and regional supply with the manufacturer or dealer. | 2026-10-26 |
Evidence map
1 of 25 measurements have records. Each column shows a kind of evidence, not a performance rating. Select a count to read the records.
| Measurement | Manufacturer reported | Demonstrated | Community tested | Independently benchmarked |
|---|---|---|---|---|
| Autonomy | ||||
| Autonomous completion | No records | No records | No records | No records |
| Failure recovery | No records | No records | No records | No records |
| Intervention burden | No records | No records | No records | No records |
| Intervention frequency | No records | No records | No records | No records |
| Novelty degradation | No records | No records | No records | No records |
| Endurance & reliability | ||||
| Charging time | No records | No records | No records | No records |
| Energy per task | No records | No records | No records | No records |
| Mission failure rate | No records | No records | No records | No records |
| Working runtime | 1 | No records | No records | No records |
| Interaction | ||||
| Human setup time | No records | No records | No records | No records |
| Instruction following | No records | No records | No records | No records |
| Response latency | No records | No records | No records | No records |
| Manipulation | ||||
| Door opening | No records | No records | No records | No records |
| Fine manipulation | No records | No records | No records | No records |
| Multistep execution | No records | No records | No records | No records |
| Object retrieval | No records | No records | No records | No records |
| Unfamiliar-object grasping | No records | No records | No records | No records |
| Mobility | ||||
| Load carrying | No records | No records | No records | No records |
| Obstacle avoidance | No records | No records | No records | No records |
| Room navigation | No records | No records | No records | No records |
| Stair climbing | No records | No records | No records | No records |
| Travel speed | No records | No records | No records | No records |
| Ownership | ||||
| Cost per successful task | No records | No records | No records | No records |
| Operating cost | No records | No records | No records | No records |
| Purchase cost | No records | No records | No records | No records |
— No records: not assessed, not zero performance. Some measurements may not apply to this form factor. Counts indicate documentation, not quality or independent verification.
Evidence records
Claims stay attributed. Read each record for hardware, conditions, limitations and disclosures.
1 of 1 records
| Record / measurement | Attribution / context | Result | Record date |
|---|---|---|---|
Working runtime Working runtime · manufacturer claimDJI reports 59 minutes with H30T only at 10 m/s in windless sea-level conditions until depletion; this is not endurance at maximum payload. | Manufacturer reported Omblet editorial Environment unspecified | No measured value | 2026-10-26 |
In the hands of owners
Public robot profiles, configurations and experience from the people using this model.